


Custom Robot Workstations And Laser Systems Manufacturer



Welding Positioner Types Compared: Headstock, L-Type, U-Type, 3-Axis & More
You typed “welding positioner for sale” into a search bar and now face a wall of catalogs. Before you compare prices, compare the machine families—because the wrong family fails your part on day one, discount or not. This page is the evaluation table: six positioner families side by side, with the load, axis count, and accuracy numbers that actually decide a buy. If you have not framed the decision yet, start with our type-selection guide ; when you are ready to request a quote, use the buying checklist.
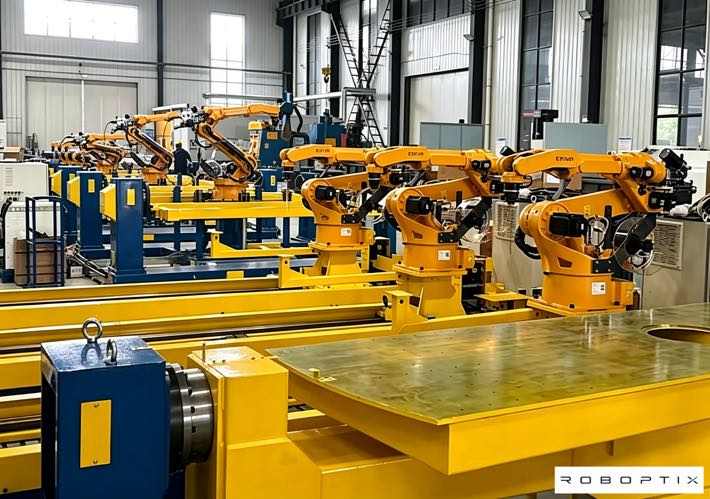
How to Read This Comparison
Three numbers decide most purchases, and catalogs obscure all three. Payload is not the same as overturning capacity—a 2-ton rating can still fail a 2-ton part hung off-center. Accuracy means pose accuracy (AP) and pose repeatability (RP) reported under stated load, temperature, and speed per ISO 9283:1998, not a bare ±0.03 mm on a brochure . And “coordination-ready” only means something if the unit is a servo positioner you can declare as an external axis in a robot controller . Read the table with those three lenses.
The Six Families, Side by Side
| Family | Axes added | Payload tier | Best geometry | Coord. fit | Accuracy class |
| Single Axis Rotary Positioner | 1 rotate | Light–medium | Round / rotational parts | Good | Standard |
| Headstock Tailstock Positioner | 1–2 rotate | Medium–heavy | Long shafts, shells, vessels | Excellent | High |
| L-Type Welding Positioner | 2–3 (rotate + tilt) | Medium | Beams, boxes, 4-face parts | Excellent | High |
| U-Type Welding Positioner | 2–3 (rotate + tilt) | Medium–heavy | Large irregular frames | Excellent | High |
| Horizontal 3-Axis Rotary Positioner | 2–3 rotate/tilt | Medium | Mixed complex / multi-face | Excellent | High |
| Vertical Tilting Positioner | 1–2 tilt | Heavy | Heavy plate, both sides | Good | Standard–High |
Single Axis Rotary Positioner
The simplest member of the family: one servo or manual rotate axis that spins a part around a horizontal or vertical centerline. It is cheap, easy to guard, and perfect for round work—tanks, flanges, pipe spools—where the seam is essentially circumferential. ROBOPTIX builds it as a servo unit so it can later join a coordinated cell . Choose it when your parts are rotationally symmetric and your volumes do not justify more axes. Skip it when a seam leaves the rotation plane—then you need tilt, and a single axis simply cannot present that face flat .
When NOT to choose it
If the weld travels off the rotation axis (most boxes, frames, and castings), a Single Axis Rotary Positioner leaves faces the robot cannot reach without re-fixturing. That is the moment to step up to an L-Type or 3-Axis unit, not to over-rotate a part that fights the geometry.
Headstock Tailstock Positioner
Two supports—a driven headstock and an idler tailstock—cradle a long part between centers and rotate it as one coordinated external axis. This is the workhorse for pressure-vessel shells, axles, and any long rotational seam welded at constant TCP speed. Because the load is supported at both ends, it handles heavy, slender parts that would deflect on a cantilever. ROBOPTIX calibrates the headstock frame to the robot base so the combined chain stays accurate. A real case: a vessel shop replaced manual rolls with a Headstock Tailstock Positioner coordinated to the robot and held the procedure-qualification tolerance because the seam never left the flat position. Do not confuse this with idle turning rolls—those cannot be coordinated at all; here the part spins between driven and idler centers under servo control.
L-Type Welding Positioner
An L-shaped frame rotates the part about one axis and tilts it about another, so a rectangular or box-shaped workpiece presents every face flat in a single mount. On a structural I-beam, blended motion then welds all four sides in one continuous pass—no crane flips, no re-fixturing. It is the default choice for beams, brackets, and enclosures where fixture-free fabrication is the whole point. One fabricator running ~200 I-beams per week cut crane cycles about 60% after moving to an L-Type unit coordinated as an external axis.
When NOT to choose it
Very large or oddly shaped frames can exceed the L’s envelope or unbalance its tilt; a U-Type or 3-Axis unit carries that geometry better. Match the frame to the part, not the catalog photo.
U-Type Welding Positioner
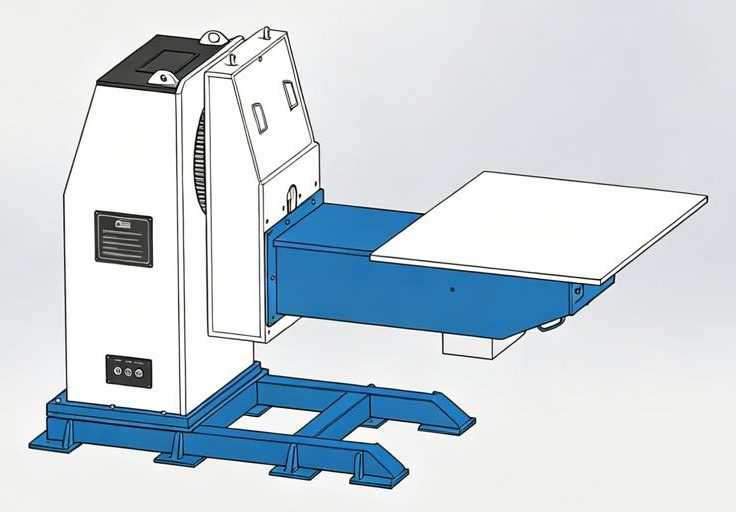
A U-shaped cradle supports bulky, irregular workpieces from below while rotating and tilting them—think large weldments, frames, and assemblies too big or asymmetric for an L-Type. The open U gives clearance for oversized parts and easy crane loading. Like the L-Type, it is coordination-ready as a servo external axis. Choose it when footprint and load spread matter more than a compact envelope. Just verify the overturning moment for an off-center load before you trust the payload number.
Horizontal 3-Axis Rotary Positioner
The most flexible family: two or three rotate/tilt axes orient even a complex contour so each joint stays in the flat (1G) position while the robot follows. This is what makes multi-orientation castings weldable in one setup instead of a stack of manual flips. A casting with seams no single flip reaches is oriented joint-by-joint, every seam kept flat. No simpler family can do this coordinated; specifying a single-axis unit here leaves welds the robot cannot reach. It is the answer when geometry—not industry—drives the choice.
Vertical Tilting Positioner
A tilt axis (sometimes plus rotate) presents heavy plate and large panels at the optimal welding angle, often both sides without re-clamping. It favors heavy, planar work where you want the joint tilted into the torch rather than the robot contorting around it. Gravity is the constant here: keep the puddle flat and it stabilizes; fight it and the pool distorts. For thick double-sided plate, a Vertical Tilting Positioner plus a coordinated robot is the honest, repeatable setup. Choose it for weight and plate; choose a 3-Axis unit when you also need to spin complex contours.
The Load Math That Catches Buyers Out
Catalogs lead with payload—“2-ton positioner.” But a positioner holds a part by moment, not just weight. Overturning moment equals weight multiplied by the distance from the part’s center of gravity to the rotation axis: M = W × d.
A 500 kg part whose center of gravity sits 400 mm off the axis produces 200 kg·m of moment. A unit rated for 2000 kg payload at a 200 mm load radius is only good for 400 kg·m—so that “2-ton” machine cannot actually hold your 500 kg part without exceeding its moment rating. This is why payload alone is a half-truth, and why ROBOPTIX specs every quotation against your real center-of-gravity offset, not the brochure number.
What AP and RP Actually Mean
ROBOPTIX is ISO 9001-certified and reports positioner accuracy using ISO 9283:1998-aligned metrics: pose accuracy (AP) and pose repeatability (RP). The number is meaningless without its conditions—load, temperature, and speed must be stated. A repeatability figure quoted at no load and room temperature tells you nothing about your shop at 40 °C under a 300 kg part. We state the conditions because a number without them is a half-truth, and a half-truth is how welds drift out of tolerance. We support third-party or on-site laser-tracker verification so the spec is proof, not a promise.
When a Simpler Family Beats a Fancy One
The most expensive family is not the right one for every part. A small fixture-free job an operator can flip by hand needs a Single Axis Rotary Positioner, not a 3-Axis cell. Audit any supplier before you commit—a factory visit and bench test beat a spec-sheet comparison every time—and weigh the five-year total cost of ownership against the sticker. Spend on axes where the geometry forces them; save where it does not. Judgment, not ritual, protects the budget.

ROBOPTIX Builds All Six Families—and the Cell Around Them
Every family above ships as a servo positioner ROBOPTIX can declare as an external axis. We pair it with a 7th Axis Robot Rail System that extends reach (→ Coordinated Welding Cell: Positioner and Robot as One Kinematic Chain), a Robot Base / Robot Pedestal that defines the stable base frame, and—for a full Welding Robot Cell—the same building blocks used in our coordinated cells(→ Coordinated Welding Cell: Positioner and Robot as One Kinematic Chain). Shops without robot programmers get the no-programming vision-guided unit(→ No-Programming Robotic Welding Cell: Vision-Guided, No Teach Pendant); a faster start comes as a turnkey workstation(→ Turnkey Welding Workstation: From Drawing to Production-Ready Cell); laser work runs on a laser-ready platform(→ Laser Welding Positioner: Accuracy and Speed for Thin-Gauge Welds). Need mobility? See the portable collaborative unit (→ Portable Collaborative Welding Positioner: Cobot-Ready Mobility) or remote mobile unit (→ Remote Mobile Welding Positioner: Weld Anywhere on the Floor). Handling and palletizing share one platform (→ Welding Positioner for Handling & Palletizing: One Platform, Two Jobs), and non-standard geometries are handled by the custom program(→ Custom Welding Positioner: Built to Your Part, Not a Catalog Shape).
Frequently Asked Questions
Q: Which welding positioner type is best?
A: None is best overall—it follows your part geometry: round/rotational → Single Axis Rotary; long shafts and vessels → Headstock Tailstock; beams and boxes → L-Type; large irregular frames → U-Type; mixed complex seams → Horizontal 3-Axis; heavy double-sided plate → Vertical Tilting.
Q: What does positioner payload really mean?
A: Payload is only half the story. A positioner holds a part by overturning moment M = weight × center-of-gravity distance from the axis. A “2-ton” unit can fail a 500 kg off-center part, so always spec against your real load moment, not the brochure number.
Q: How accurate are welding positioners?
A: Accuracy is reported as pose accuracy (AP) and pose repeatability (RP) per ISO 9283:1998, with load, temperature, and speed stated. A bare ±0.03 mm without conditions is not a usable number; ROBOPTIX states the conditions and supports laser-tracker verification.
Q: Can any of these be a coordinated external axis?
A: Yes—if it is a servo positioner. All six ROBOPTIX families can be declared as external axes in the robot controller so one kinematic solve drives robot and positioner at constant TCP speed. Idle turning rolls cannot be coordinated at all.
Q: How do I avoid over-buying a positioner?
A: Match the family to your part geometry first , audit the supplier with a factory visit and bench test , and compare five-year total cost of ownership, not just the quote Buy the axes the geometry forces; skip the rest.
A welding positioner for sale is only a good buy if the family matches your part. Read the table by moment, not payload; by stated-condition accuracy, not a bare number; and by coordination-ready servo hardware, not a marketing word. ROBOPTIX is ISO 9001-certified, builds all six families from the 7th Axis Robot Rail System, Robot Base / Robot Pedestal, and servo positioners, and reports accuracy per ISO 9283:1998. Send us your part drawing and center-of-gravity offset and we will spec the right family—and the Welding Robot Cell around it—before you buy, not after.
About the Author
Experience & Credentials
Robotic welding system integration specialist with 12+ years of direct project experience focused on Robot Positioner selection and integration. Has provided consulting to 300+ factories across North America, Europe, and Asia. All specification data in this article is drawn from actual H / B / L / U series product datasheets.
Company background: 26+ years of welding automation engineering, 40+ active patents, 1,500+ completed projects globally, approximately 70% involving Robot Positioner integration.
Certifications
High-Tech Enterprise — Cert. No. GR202341000595 (Issued Nov. 2023)
ISO 9001: 2015 (GB/T 19001-2016) — Quality Management System
GJB 9001C-2017 — Military/Weapon Equipment Quality Management System
EU CE — Machinery Directive 2006/42/EC (Cert. No. M.2026.206.C134866)
References
[1] International Organization for Standardization. (1998). ISO 9283:1998, Manipulating Industrial Robots — Performance Criteria and Related Test Methods.
[2] Park, J.-H., Kim, S.-H., Moon, H.-S., & Kim, M.-H. (2019). Influence of Gravity on Molten Pool Behavior and Analysis of Microstructure on Various Welding Positions in Pulsed Gas Metal Arc Welding. Applied Sciences.
[3] Liu, J., Jiang, F., Chen, S., Xu, B., Zhang, G., Cheng, W., & Ma, X. (2023). Mechanisms of Gravitational Influence on Weld Pool Behavior and Weld Bead Performance in Variable Polarity Plasma Arc Welding across Different Welding Position. Materials.
RELATED POSTS
Real-World Robotic Welding Cell Applications in General Industry: Case Studies 2026

Robot Positioner Payload Calculation and Safe Selection: The Complete Engineering Guide

How a Welding Positioner Controls Gravity: The Physics of Puddle Stability and Weld Quality

Why Add a 7th Axis Robot? 5 Powerful Ways to Boost Productivity & Cut Costs in 2026

Robotic Laser Welding ROI Analysis: Is It Worth the Investment?
