


Fabricante de sistemas láser y estaciones de trabajo robóticas personalizadas



La guía completa para principiantes sobre posicionadores de robots: Todo lo que necesitas saber
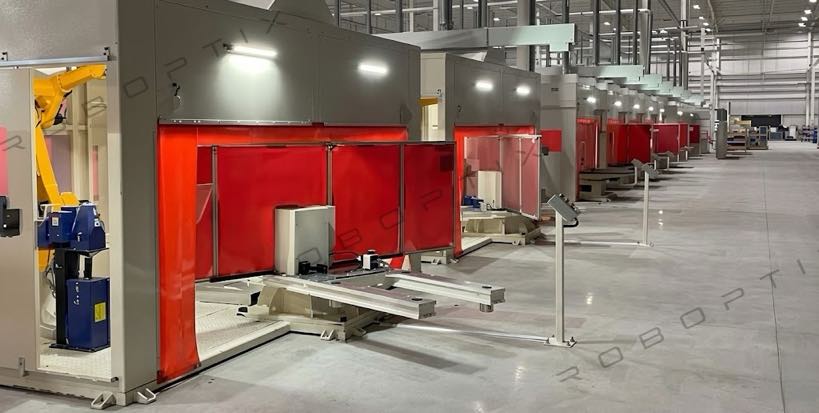
A Plain-Language Guide to Robot Positioners — No Background Required
If you are just starting to explore welding automation, Probablemente te hayas encontrado con el término "Posicionador de robot".’ without being entirely sure what it is, how it works, or how it relates to a welding robot. This guide is written specifically for you.
Whether you are a factory owner evaluating your first automation investment, a purchasing engineer responsible for equipment selection, or a technical professional new to this field, by the end of this article you will understand:
- What a Robot Positioner is and what problem it solves
- How it works and what its core functions are
- The main types available and how they differ
- The real operational value it delivers to a factory
- The key specifications to understand before buying — and the most common selection mistakes
We will not pile on technical jargon. Every concept is explained in terms you can grasp immediately. If you have follow-up questions about a specific product after reading, there is a free consultation link at the end.
¿Qué es un posicionador de robot??
The One-Sentence Definition
A Robot Positioner is a servo-driven precision rotation device that automatically adjusts the spatial orientation of a workpiece during welding or assembly, so that the welding robot can always access every joint at the optimal angle.
If that still sounds abstract, here is a simple way to think about it:
| Everyday analogy: Imagine cooking meat on a rotisserie — you continuously rotate the spit so every side gets even heat. A Robot Positioner does exactly the same thing: it continuously rotates and tilts the workpiece so the welding torch always faces the easiest side to weld, rather than forcing the robot to reach into awkward corners. |
How a Robot Positioner Relates to a Welding Robot
A common first question is: a six-axis welding robot is already highly flexible — why would you need another piece of equipment?
The answer is that robot flexibility solves the question of where the torch goes. A Robot Positioner solves the question of how the workpiece is oriented. They have different jobs, and combining them is what unlocks the full performance potential of a robotic welding cell.
| Dimensión | Robot de soldadura | Posiciones de robots |
| Primary role | Controls torch path and welding parameters | Controls workpiece spatial orientation |
| What it moves | The torch | The workpiece |
| Problem it solves | Weld path accuracy | Weld position (departamento / vertical / arriba) |
| Used alone | Sí, but efficiency is limited | Typically paired with a welding robot |
| Used together | ✅ Coordinated axis control — efficiency and quality both maximized | ✅ Workpiece always in the optimal welding attitude |
When the two work together in coordinated axis control mode, the Robot Positioner rotates the workpiece while the welding robot simultaneously adjusts the torch position — the two axes move in real-time synchronization, with no arc interruption. The core advantage of this mode: the robot always welds in the flat or horizontal position — the position where physics makes it easiest to achieve a high-quality weld.
How a Robot Positioner Works: 3 Core Motions
Understanding a Robot Positioner comes down to three fundamental motions:
Motion 1: Rotation — Spinning the Workpiece
Continuous rotation around the primary axis, with a typical range of unlimited ±360° rotation. This is most commonly used for cylindrical or elongated workpieces — pressure vessel shells, shaft components, circular flanges. The workpiece rotates while the torch holds a fixed position and welds continuously. This is the so-called ‘workpiece moves, torch stays’ mode, which increases arc-on time from the manual welding average of 35% a 85% o superior.
Motion 2: Voltear / Tilt — Changing Workpiece Orientation
Rotation around a horizontal or inclined axis, típicamente ±90° to ±135°, to bring different weld faces to the upward or horizontal position. For multi-face workpieces such as square frames or equipment housings, the flip function means every weld face can be presented to the torch in the flat welding attitude, completely eliminating vertical and overhead welding.
Motion 3: Precision Positioning — Lock and Hold
Both rotation and flip motions are servo-driven through precision gearboxes, achieving positional repeatability of ±0.03 mm to ±0.075 mm depending on model. The system locks automatically once the target position is reached, ensuring that every time the welding robot strikes an arc, the workpiece is in a repeatable, traceable position — eliminating weld seam offset from positional variation.
| Key concept: The Robot Positioner’s rotation speed and angle are fully synchronized with the welding robot’s motion through real-time position signal exchange between controllers. This means the arc does not need to stop during repositioning — the workpiece moves, welding continues, and production efficiency increases substantially. |
Robot Positioner Types: A Plain-Language Overview
Robot Positioners are available in five structural categories, each suited to different workpiece shapes, weights, and welding process requirements. Here is a straightforward introduction to each type — if you are not yet sure which one you need, read through all five and then refer to the selection guidance at the end.
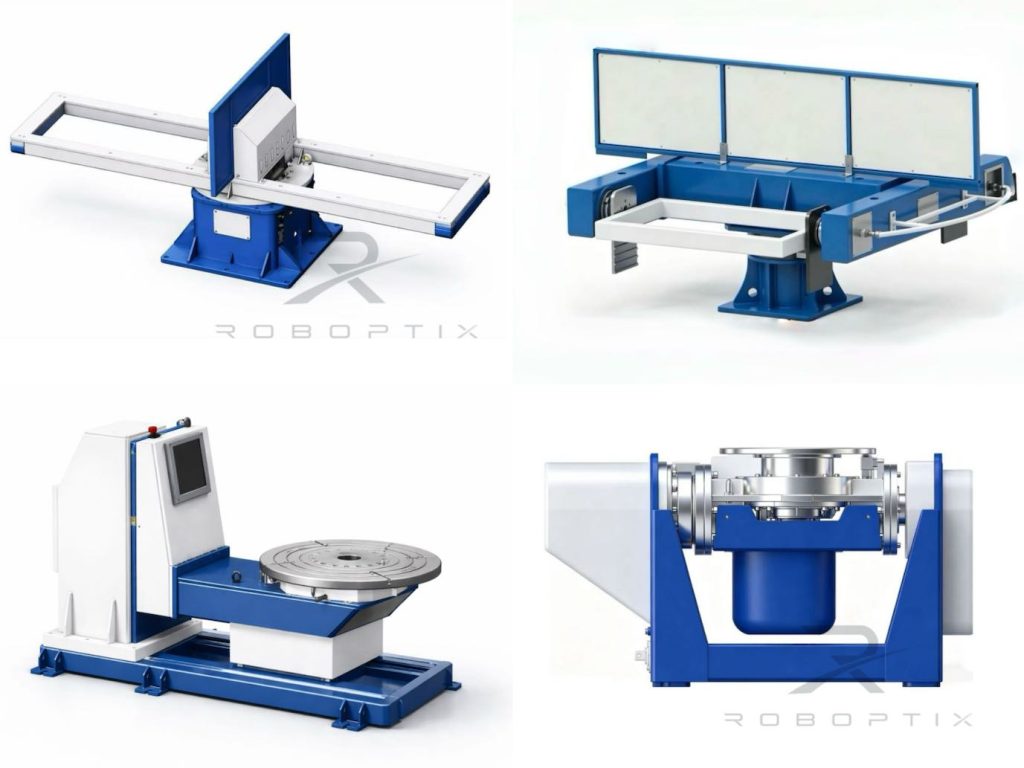
| Posicionador de robot de cabezal y contrapunto | Serie B| 500–5.000 kilogramos |
| The workpiece is supported at both ends: one end by a servo-driven head, the other by a passive tailstock. The workpiece is mounted between them like a rotisserie and rotates freely along its primary axis, while the welding robot welds along the workpiece’s length.Best suited for long, tubular, or axially symmetric workpieces. For circumferential welds (ring seams, costuras longitudinales), this configuration allows continuous arc contact as the workpiece rotates — the highest arc-on time of any Robot Positioner type.Typical applications: Carcasas para recipientes a presión, large shaft components, secciones de torre de turbina eólica, engineering machinery arms, pipe assemblies| Carga útil: 500–5.000 kilogramos (MRK-B001 / B002 / B004) |
| Mesa de servorotación tipo H | Serie H| 300–2.000 kilogramos |
| A horizontally mounted circular table that rotates around a vertical axis. The workpiece is fixed to the table surface, and the table rotates to bring the workpiece to the correct welding angle. estructura sencilla, intuitive operation — the easiest Robot Positioner type to get started with.Well-suited to disc-shaped, en forma de anillo, or planar workpieces, and to assemblies requiring indexed positioning after assembly. Standard table diameters range from 600 mm a 2,500 milímetros, covering a wide range from light to heavy workpieces.Typical applications: Flange welding, marcos circulares, carcasas de motores, EV battery tray welding| Carga útil: 300–2.000 kilogramos (MRK-H001–H005) |
| Posicionador de robot de doble eje tipo L | Serie L| 300–1.500 kilos |
| An L-shaped frame design with two independent servo axes: a horizontal rotation axis (tooling axis) and a vertical flip axis. The workpiece can first be rotated to the correct orientation on the horizontal axis, then tilted to the optimal angle by the flip axis — two-axis coordination for more flexible workpiece attitude control.Suited to medium-sized workpieces that require welding from multiple directions, and commonly used at combined welding and assembly stations to eliminate fixture changeover time.Typical applications: Marcos de baterías para vehículos eléctricos, marcos de motocicleta, aluminum weldments, medium equipment housings| Carga útil: 300–1.500 kilos (MRK-L001 / L002) |
| Posicionador de robot de doble eje tipo U | Serie U| 300–1.000 kilogramos |
| A U-frame design with J1 flip axis (±90°) y eje de rotación J2 (±200°). The two axes work in coordinated motion to tilt any face of the workpiece to the upward flat welding position. Huella compacta, high repeatability (up to ±0.05 mm), and well-suited to space-constrained welding cells.The highest automation integration level among entry-level dual-axis Robot Positioners, particularly suited to batch production of multi-face welded components.Typical applications: Soportes estructurales automotrices, marcos del panel de instrumentos, standard robotic welding cell configurations| Carga útil: 300–1.000 kilogramos (MRK-U001 / U002) |
| Three-Axis Servo Robot Positioner | Serie B008–B012| 300–2.000 kilogramos |
| Three coordinated servo axes: a rotation axis, un eje de herramientas (rotación), and a large-diameter swing. This configuration handles the most geometrically complex workpieces. No matter how many weld faces a component has or how widely distributed the seams are, three-axis coordination brings each one to the flat position in sequence without any manual reorientation.The definitive solution for complex heavy weldments, most widely used in construction machinery, wind energy equipment, and heavy structural steel fabrication.Typical applications: Excavator boom arms, crane slewing rings, marcos de góndola de turbina eólica, multi-face heavy structural weldments| Carga útil: 300–2.000 kilogramos (MRK-B008–B012) |
What Value Does a Robot Positioner Deliver to a Factory?
The most common question from factory owners considering a Robot Positioner is straightforward: is this investment worth it? The following breaks down the answer across four dimensions, all supported by real data.
1. Efficiency: 50–100% Capacity Increase
En operaciones de soldadura manual, the percentage of working hours actually spent welding (tiempo de arco) averages just 35%. The rest is consumed by workpiece repositioning, crane lifting, and waiting. After Robot Positioner integration:
- Workpiece repositioning time: from 15–25 minutes per event → 5–10 seconds
- tiempo de encendido del arco: de 35% → 78–88%
- Single station output: equivalent to 2–3 manual welding stations
| Project data: A través de nuestro 1,500+ completed installations, factories report average production capacity increases of 50–100% with the same headcount. On large workpiece welding operations, some installations exceed 130% capacity increase. |
2. Calidad: 40–88% Defect Rate Reduction
The root cause of quality improvement is simple: every weld is completed in the flat or horizontal position rather than compromised in overhead or vertical positions. En posición plana, gravedad, gas de protección, and arc force all work together — the physics of the position itself ensures weld quality.
- Incidencia de porosidad: average reduction of 80%
- Vender a menor precio que / llenar insuficientemente: average reduction of 90%
- Tasa general de defectos: average reduction of 40–60%, peak results exceeding 85%
- Tasa de aprobación de la inspección de primer paso: from a typical 65–75% → 95%+
3. Seguridad: 80–90% Reduction in Workpiece Handling Incidents
Manual repositioning of large workpieces is among the most hazardous operations in a welding shop — overhead cranes, eslingas, swinging loads. Every repositioning event is a discrete safety exposure.
- After Robot Positioner installation, workpiece rotation is controlled by servo motors with no manual intervention
- Workpiece handling incidents (including minor injuries) decrease by 80–90%
- Workers transition from physical labor roles to equipment monitoring roles, with significantly lower occupational injury rates
- Safety audit pass rates improve; trabajadores’ compensation premiums decrease in many cases
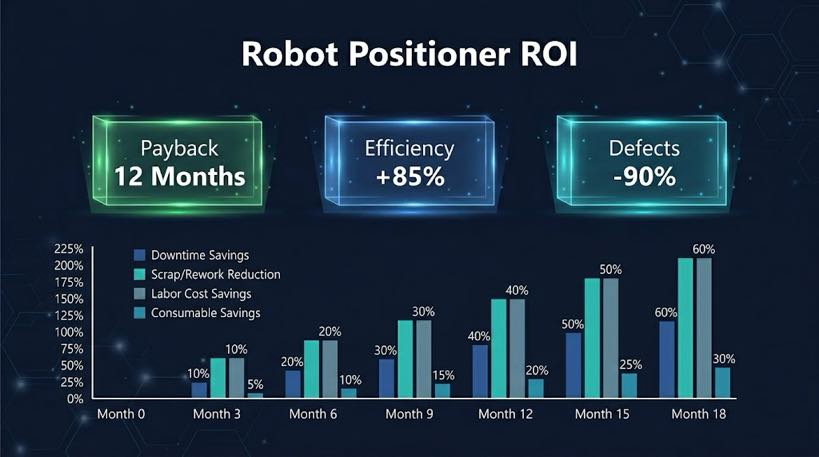
4. Costo: 8–16 Month Payback Period
The cost savings from a Robot Positioner come from multiple stacked sources:
| Cost Saving Source | Typical Saving |
| Reduced rework and repair labor | Annual savings of $30,000–$150,000 (depends on original defect rate) |
| Reduced overtime costs | Average overtime hours reduced by 60% |
| Lower workers’ compensation and insurance | Premiums decrease as handling incidents fall |
| Extended productive careers for skilled welders | Reduced hidden cost of early retirement from occupational injury |
| Lower recruitment and training costs | 1 Robot Positioner replaces output of 2–3 manual welders |
| Payback reference: Small shops (annual revenue $1M–$5M): investment $45,000–$75,000, venganza 8–14 meses. Medium shops ($5M–$20M): investment $100,000–$250,000, venganza 10–16 meses. Figures based on documented customer installation data. |
What You Need to Know Before Buying
Before contacting a supplier for a quotation, it is worth clarifying the following key specifications. Understanding these will help you describe your requirements accurately and avoid being guided toward an unsuitable configuration.
Key Specifications Explained
1. Carga útil nominal
Rated payload is the maximum workpiece weight the Robot Positioner can drive reliably, expressed in kilos. Important: payload = workpiece weight + fixture weight combined — do not calculate the workpiece alone. Por ejemplo, an 800 kg workpiece with a 150 kg fixture requires a model rated at no less than 950 kilos.
The market range runs from 300 kilos (light duty) a 5,000 kilos (heavy duty). When selecting, allow a 20% margin above your actual maximum load to avoid running continuously at full capacity, which degrades precision and service life.
2. Positional Repeatability
Repeatability is the range of error when the Robot Positioner returns to the same position repeatedly, expressed in mm. Higher precision = smaller number. The practical range across current product lines:
- ±0,03 milímetros: Alta precisión (B009, B011) — for structural components with strict weld position requirements
- ±0,05 milímetros: Estándar (serie h, B001/B002, U001) — sufficient for the large majority of industrial welding applications
- ±0.075 mm: Economy (B004, U002 eje de giro, B010) — for heavy workpieces where precision requirements are lower
For general structural welding, ±0.05 mm is fully adequate. Automotive precision components and thin-wall aluminum applications warrant ±0.03 mm.
3. Maximum Rotation Speed
Rotation speed affects how quickly the Robot Positioner repositions between weld faces, expressed in °/s or rpm. Faster speeds mean shorter repositioning wait times. Sin embargo: higher speed means greater rotational inertia, which places higher demands on workpiece fixturing and clamping design. For heavy workpieces, select models with controlled acceleration/deceleration (p.ej., B001: 45°/s² accel/decel) to prevent workpiece shift during high-speed repositioning.
4. Envergadura estándar / Table Diameter
Span (head-and-tailstock type): the distance between the drive head and tailstock, determining the maximum workpiece length the system can accommodate. Common standard spans: 2 metro, 2.5 metro, 3 metro, 3.5 metro (B001/B002); 3 metro, 5 metro, 6 metro, 8 metro (B004 heavy duty).
Table diameter (tipo H / tipo U): the effective load-bearing surface diameter of the table, determining the maximum workpiece outer diameter. Confirm that your workpiece’s maximum swing diameter does not exceed the model’s allowable maximum (p.ej., H005: maximum swing diameter 3,000 milímetros).
5. Control Mode: Independent Control vs. Coordinated Axis Control
| Control Mode | Descripción | Best Suited For | Trade-offs |
| Independent Control | Robot Positioner and welding robot operate independently. Welding stops during repositioning; repositioning stops during welding. | Simple workpieces, limited budget, single-face welding | ⚪ Lower cost, but arc-on time cannot be maximized |
| Coordinated Axis Control | Robot Positioner functions as an external axis of the robot. Rotation and welding occur simultaneously with real-time coordination. | Circumferential seams, complex multi-face welding, high-efficiency requirements | ✅ Arc-on time maximized, weld quality optimized — higher integration cost |
For most factories prioritizing efficiency and quality, coordinated axis control is the recommended starting point.
Common Buying Mistakes
| Misconception 1: “Bigger payload capacity is always safer — buy the largest available.” |
| Incorrect. Oversized payload ratings mean a heavier machine, higher cost, and greater rotational inertia. Select the appropriate payload tier based on your heaviest workpiece plus fixture weight, con un 20% margen. Over-specifying wastes budget without improving performance. |
| Misconception 2: “±0.03 mm precision is the only safe choice.” |
| No necesariamente. ±0.05 mm is fully sufficient for the large majority of structural steel and engineering machinery welding applications. Only automotive precision components, thin-wall aluminum, and similar high-tolerance scenarios require ±0.03 mm. Specifying unnecessarily high precision increases purchase cost and maintenance complexity. |
| Misconception 3: “A Robot Positioner eliminates the need for skilled welders.” |
| Incomplete. A Robot Positioner is an automation support device that works in conjunction with a welding robot (or welders with a certain technical foundation). Its value is enabling the same workforce to produce higher output with better quality — not a complete replacement of welding expertise. |
| Misconception 4: “Any Robot Positioner will be compatible with my existing robot.” |
| Needs verification. All major welding robot brands (FANUC, LLORAR, TEJIDO, Yaskawa, etc.) support coordinated axis control, but specific interface protocols and parameter configurations must be confirmed with the integrator in advance. Provide your existing robot model number at the quotation stage. |
| Misconception 5: “A larger span / bigger table is always better.” |
| Incorrect. Excessive span reduces the rigidity of the drive system’s control over the workpiece, degrading positional precision. An oversized table increases unnecessary rotational inertia. Select the specification that fits your most common workpiece dimensions, not the largest available specification. |
Still Not Sure Where to Start?
With the foundation from this guide in place, the logical next step is a workpiece-specific analysis. We offer a free Robot Positioner selection consultation:
- Díganos el peso de su pieza de trabajo, dimensiones, and weld joint types
- We recommend the right Robot Positioner type and control configuration
- We provide a preliminary ROI estimate to help you evaluate the investment
- Written recommendation delivered within 24 horas
► Contact us for a free Robot Positioner selection consultation
Sobre el autor
| Experiencia & Cartas credencialesEl autor es un especialista en integración de sistemas de soldadura robótica con 12+ años de experiencia directa en proyectos, focused on Robot Positioner and coordinated-axis welding system design and implementation across automotive manufacturing, heavy machinery, recipientes a presión, and new energy equipment. This article is written for newcomers to the field, translating 12 years of project experience into practical knowledge accessible to anyone. Antecedentes de la empresa: 26+ años de ingeniería de automatización de soldadura, 40+ patentes activas, 1,500+ Proyectos completados en América del Norte., Europa, y Asia, aproximadamente 70% of which involve Robot Positioner integration. One of the few manufacturers in the industry offering a complete H/B/L/U series Robot Positioner product line under a single manufacturer. Proceso de dar un título: EU CE Certification — Robot Positioner systems (Certificado No.: M.2026.206.C134866) Última revisión y actualización: Puede 2026 |
PUBLICACIONES RELACIONADAS

Una comparación completa de la soldadura láser robótica frente a. Soldadura MIG y TIG: ¿Cuál es el adecuado para usted??

2026 Guía del comprador de posicionadores de robots: Todo 5 Tipos comparados: cabezal y contrapunto, Tipo L, Tipo U, y más

Cómo elegir la celda de soldadura robótica adecuada para su taller? Estación única vs.. Dos estaciones (2026 Guía completa)

Posicionador de soldadura láser: Precisión y velocidad para soldaduras de calibre fino

Lista de verificación de compra de posicionadores de soldadura: 6 Entradas para una solicitud de cotización precisa
